Detect
Ground and distributed sensors establish a verified picture of low-altitude activity.
MATHryoshka turns uncertain drone behaviour into a physically bounded, continuously updated response problem.
AutoFly is developing an integrated response chain for uncooperative aerial threats: from detection and classification to prediction, autonomous guidance and controlled interception.
Designed for critical infrastructure, restricted zones and defence validation environments.
Each layer reduces uncertainty before the next decision is made.
Ground and distributed sensors establish a verified picture of low-altitude activity.
Multi-sensor fusion classifies the object, estimates its state and measures confidence.
MATHryoshka calculates the target's physically reachable space under uncertainty.
The system selects a controlled response and continuously replans the interceptor path.
Developed in Dr Ivan Panov's PhD research at Aarhus University, the method estimates where an uncooperative drone of an unknown model can physically move within a defined time horizon.
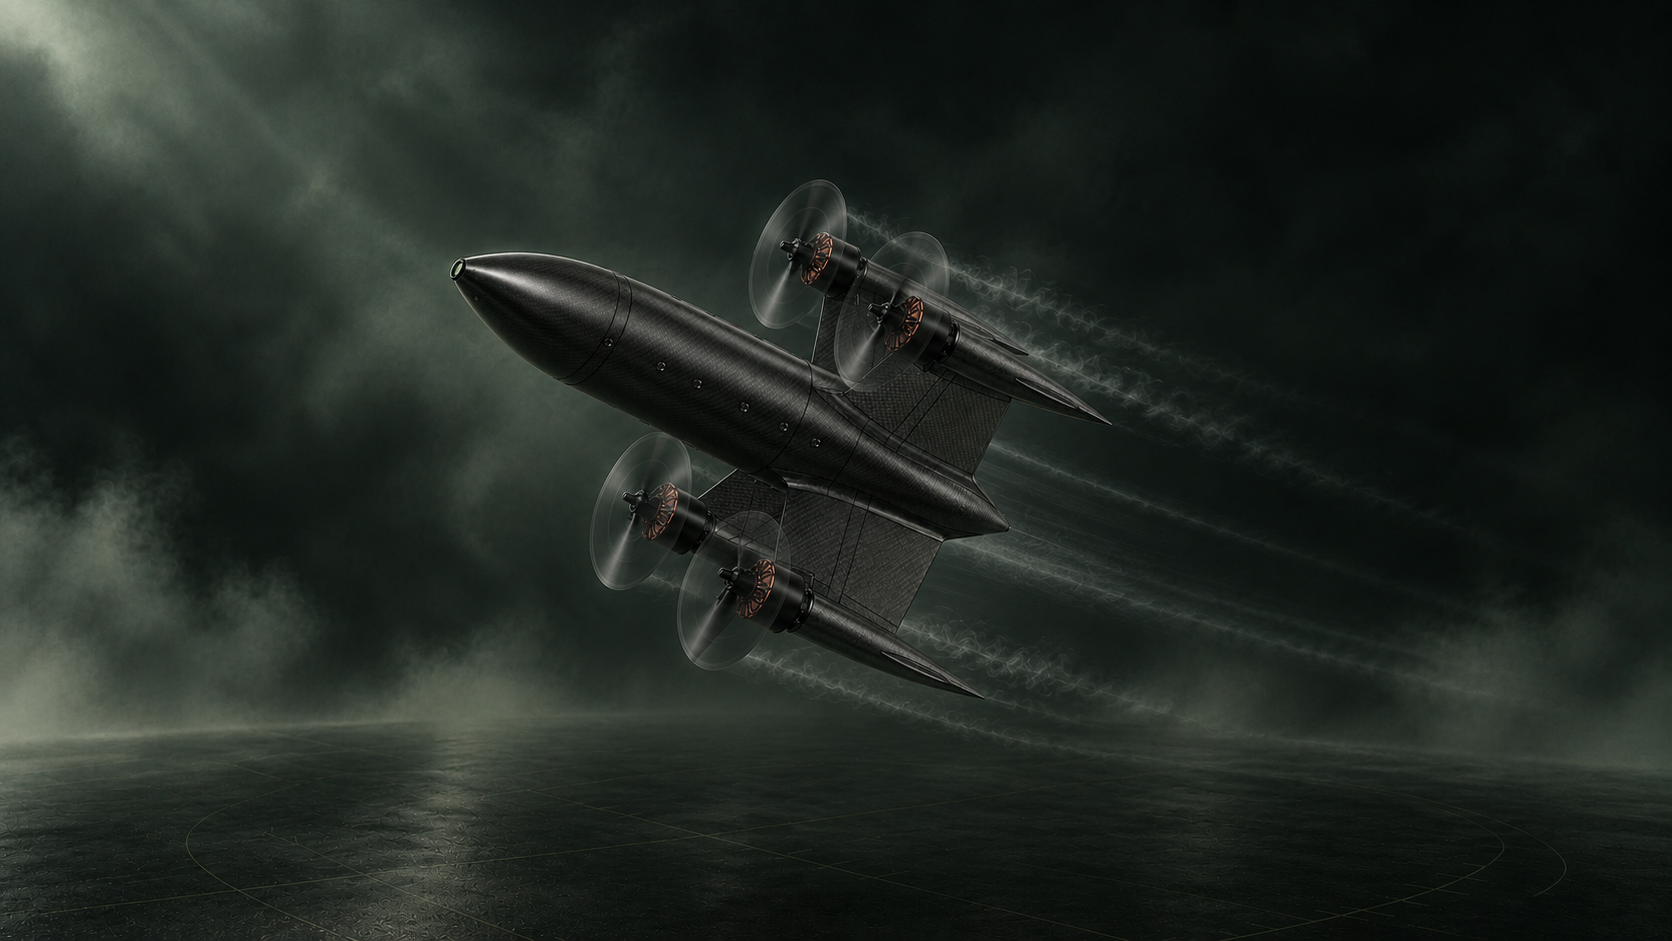
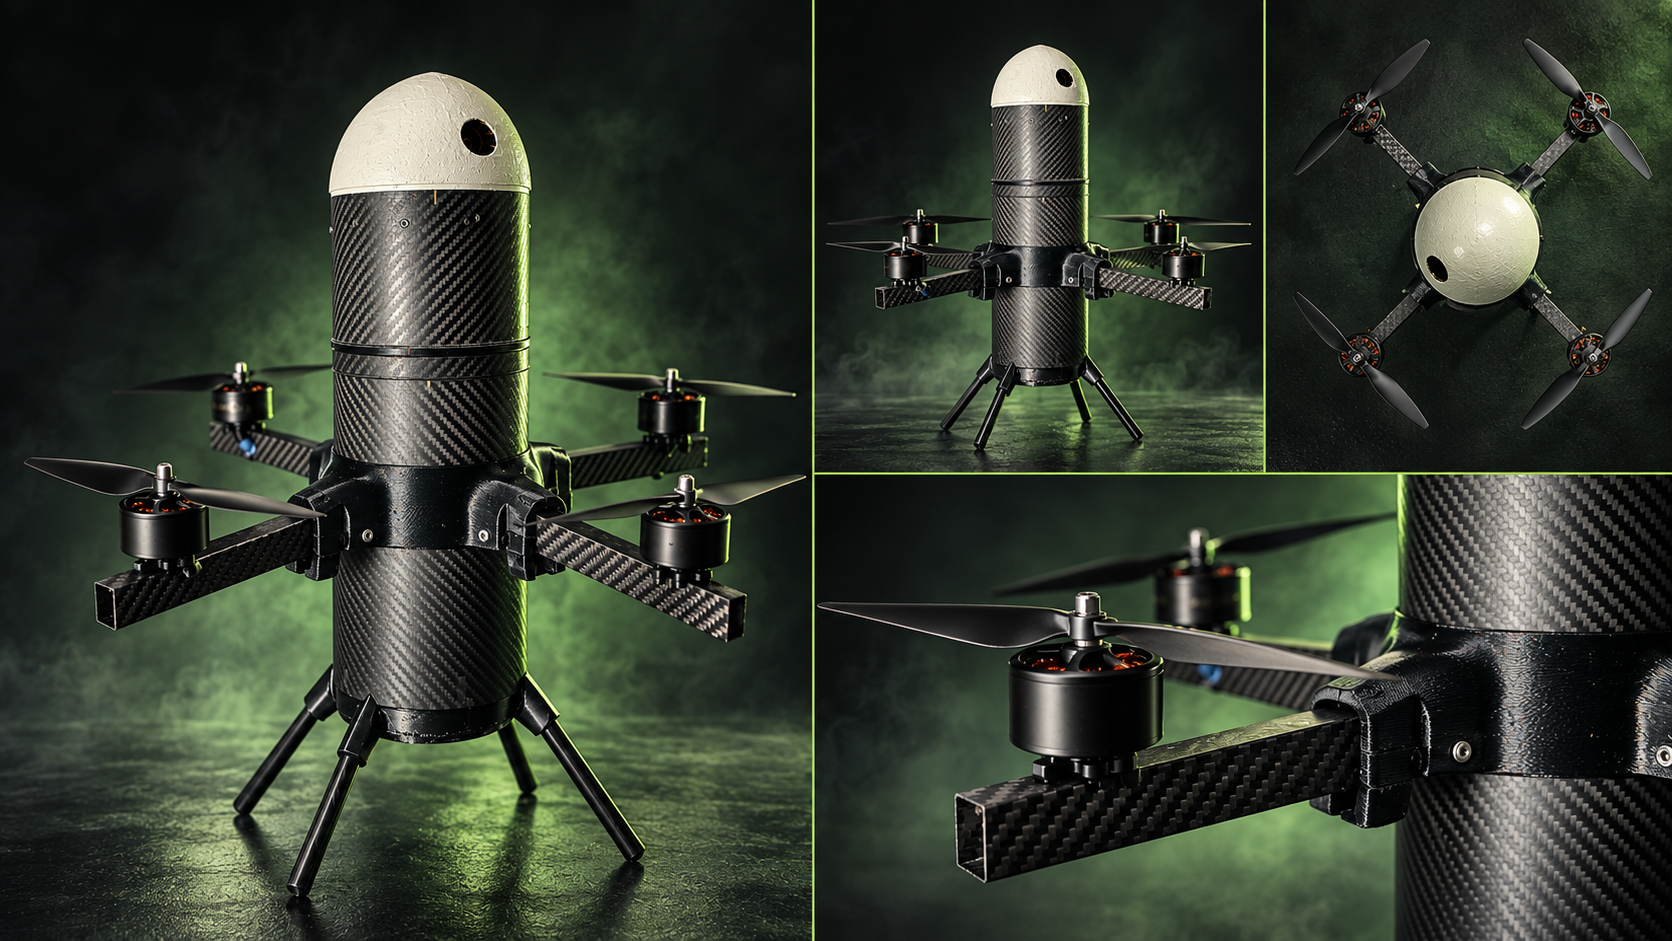
A modular fixed-wing development platform connects the mathematical prediction layer to a real, measurable flight response.
The carbon-fibre development prototype provides a physical platform for propulsion, flight-control, sensor and guidance integration.
The programme advances one measurable risk at a time.
Mathematical modelling, simulation and an existing flying platform.
CURRENT FOUNDATIONSensor inputs, autonomy stack and closed-loop guidance validated together.
INTEGRATION GATERepeatable field trials with evidence, logs, metrics and failure analysis.
PROGRAMME TARGETAutoFly AI Robotics brings together UAV development, autonomous systems research and field validation around one integrated mission.
AutoFly AI Robotics. Product direction, interceptor development and partnership programme.
PhD research in autonomous UAV operations, safe separation with uncooperative aircraft and 4-D trajectory planning.
We are opening conversations with research, validation and defence-technology partners.